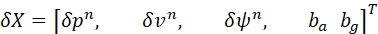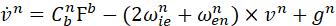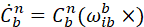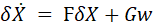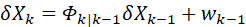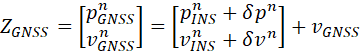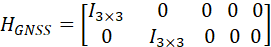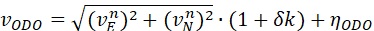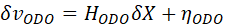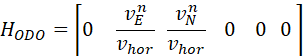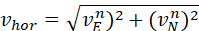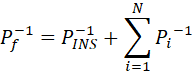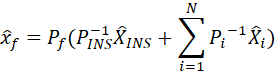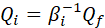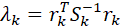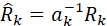
In automotive applications, individual navigation sources possess inherent limitations: Inertial Navigation Systems (INS) offer high short-term accuracy, yet their errors diverge over time; GNSS provides absolute positioning but is susceptible to signal obstruction and multipath effects; and odometry (ODO)—relying on wheel speed—yields stable velocity observations, though it is affected by wheel slip and variations in tire radius. The core challenge in multi-source fusion lies in maintaining the continuity and consistency of the navigation solution, even when observation quality fluctuates and sensor failures occur unpredictably.
The fusion system employs a federated filtering architecture, utilizing the INS as a common reference system, while GNSS and odometry serve as local filters. A master filter is responsible for information fusion and fault detection. The state vector is defined as a 15-dimensional error state:
The INS recursive equations are:
After linearization, the error-state propagation model is obtained:
GNSS provides position and velocity observations:
The observation matrix is:
The relationship between the odometer output—scalar velocity v_{ODO}—and the INS velocity is as follows:
After linearization
in
The fusion equation for the main filter of a federated filter is:
The principles for information distribution are as follows:
Fault detection using residual chi-square test:
Further introduce an adaptive factor a_k to adjust the observation noise matrix:
When GNSS signal quality degrades (e.g., a reduction in the number of visible satellites or an increase in the Dilution of Precision, DOP), the parameter $a_k$ is adaptively increased, which is mathematically equivalent to reducing the weight assigned to GNSS<
оставить сообщение
Отсканируйте QR-код для отправки в WeChat :